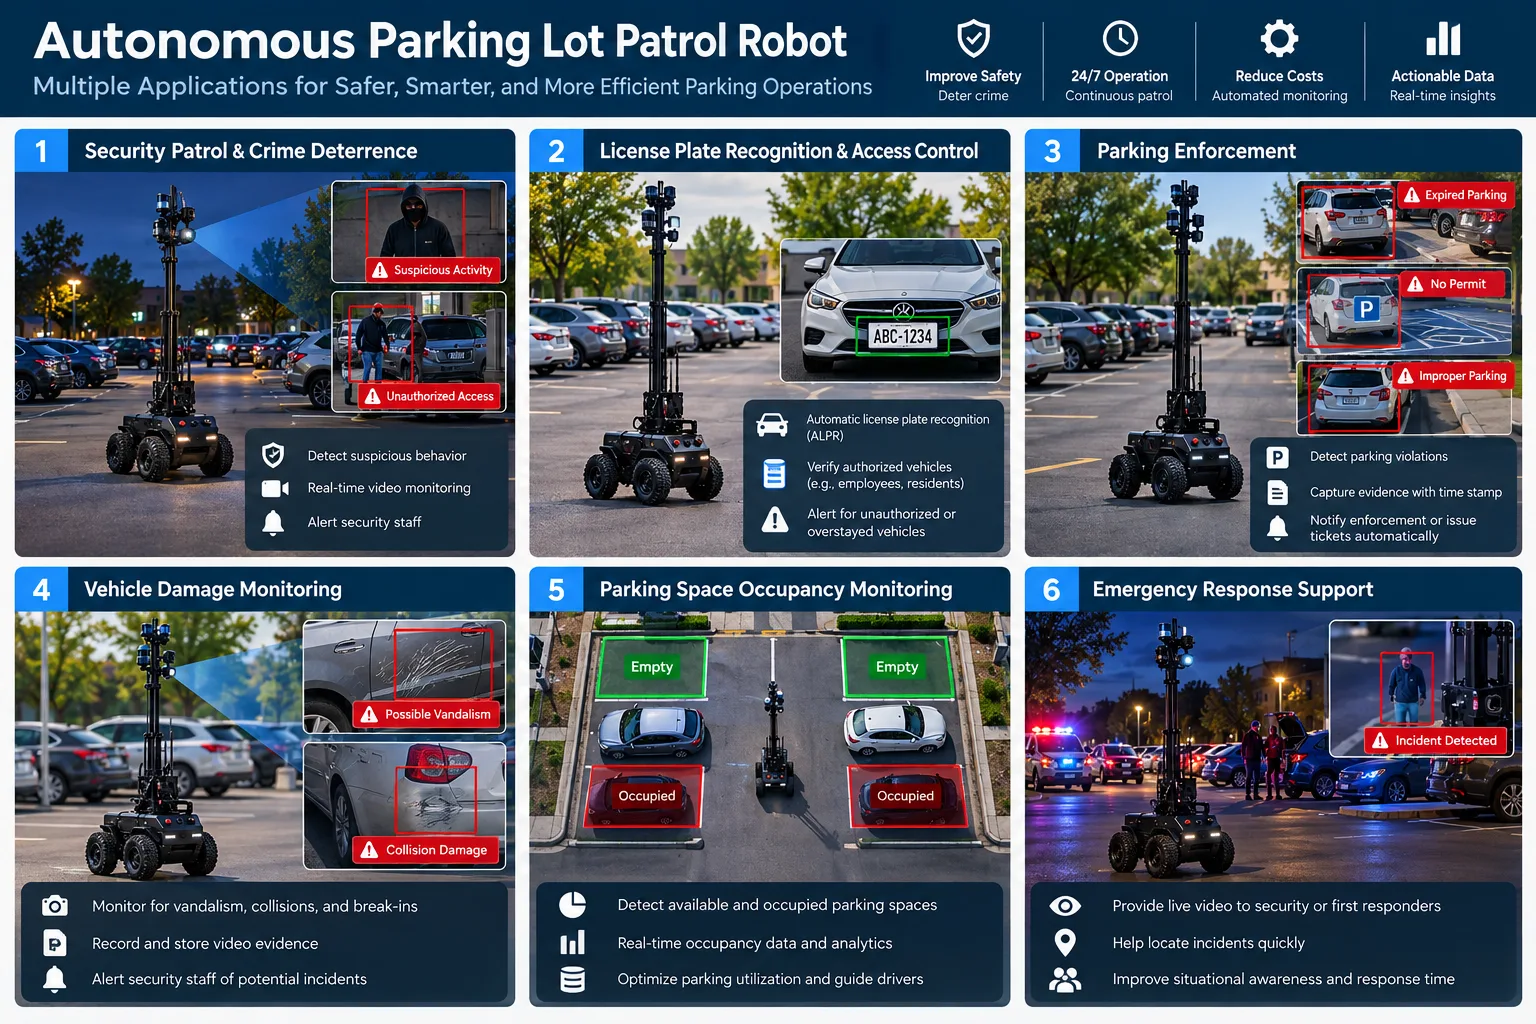
Security
Parking Lots & Campuses
Remote patrol, elevated video observation, incident awareness and optional vehicle monitoring.
Versatile robotic platforms combining mobile mobility, elevated sensing and remote operations for smarter security and industrial monitoring.
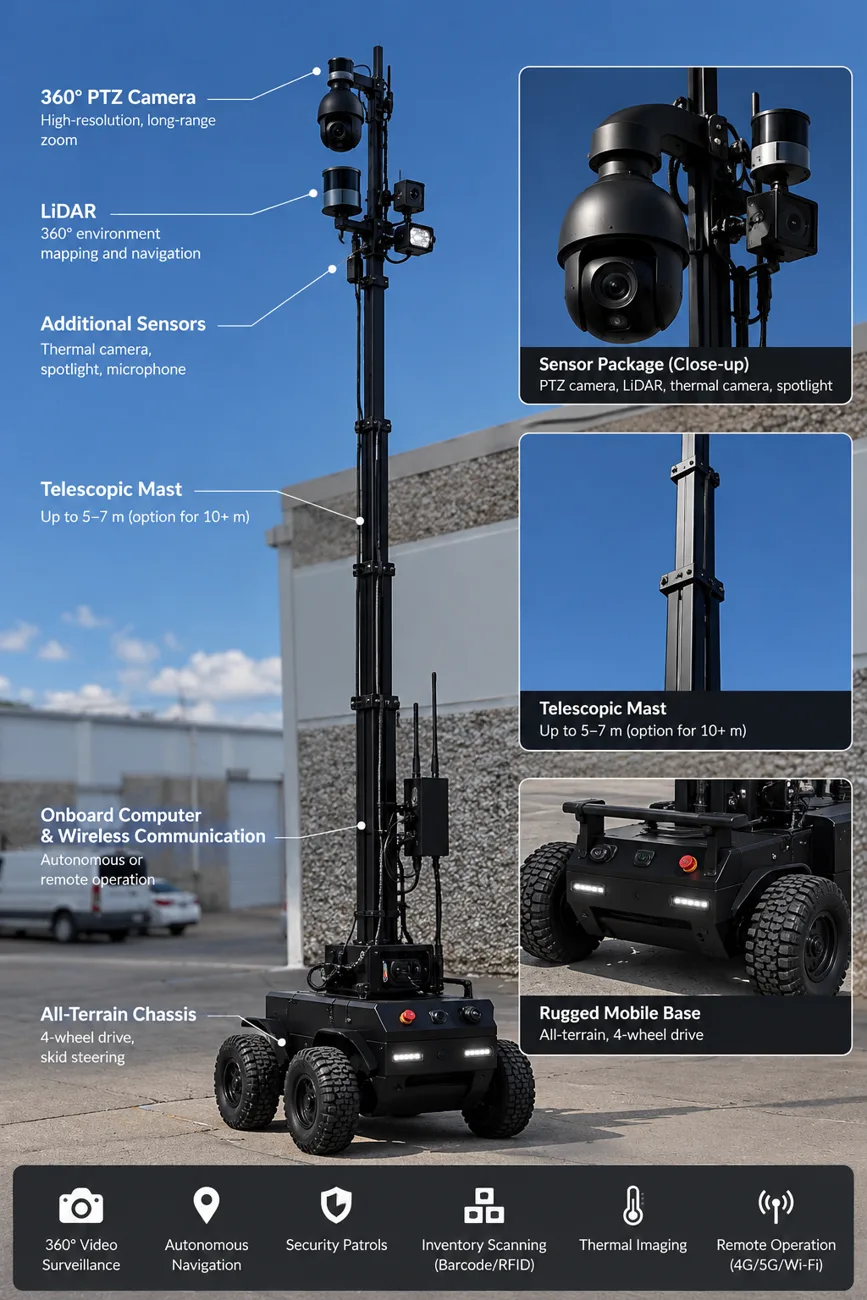
Our rugged four-wheel mobile platform integrates an electric telescopic mast with configurable cameras, sensors and communications equipment. Designed for surveillance, inspection and research across demanding environments.
Images include concept visualizations. Sensor packages and autonomy features vary by prototype and planned configuration.
A flexible platform for different monitoring challenges. The scenarios below illustrate potential applications, not verified deployed capabilities.
Remote patrol, elevated video observation, incident awareness and optional vehicle monitoring.
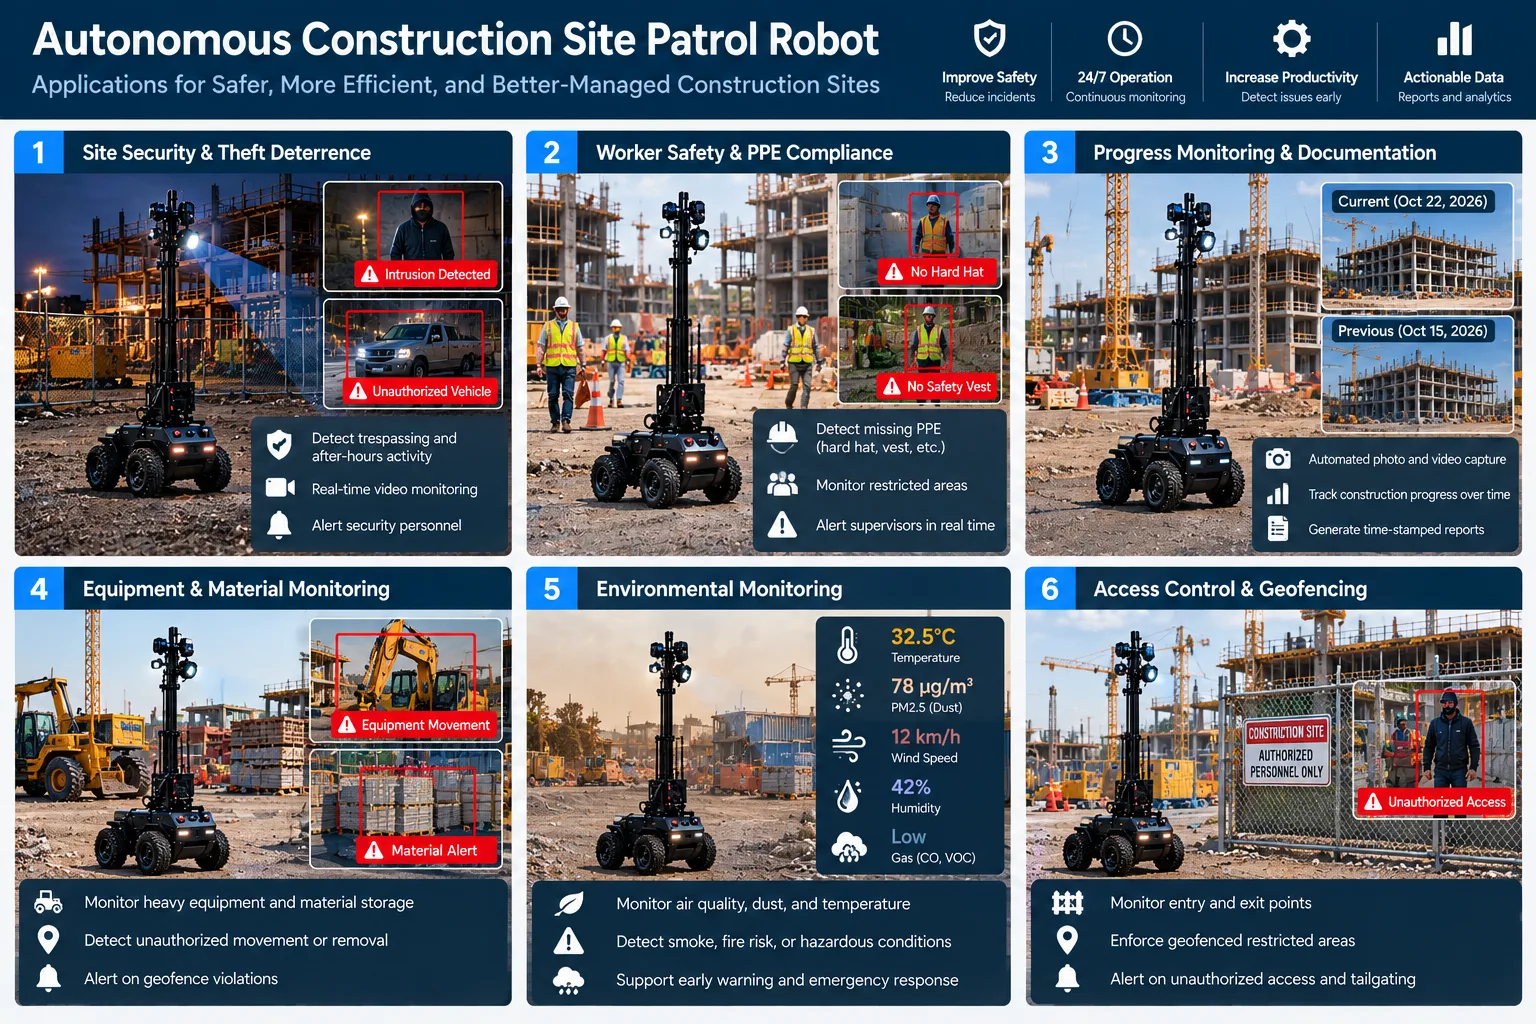
Perimeter monitoring, asset observation, safety inspections and visual progress documentation.
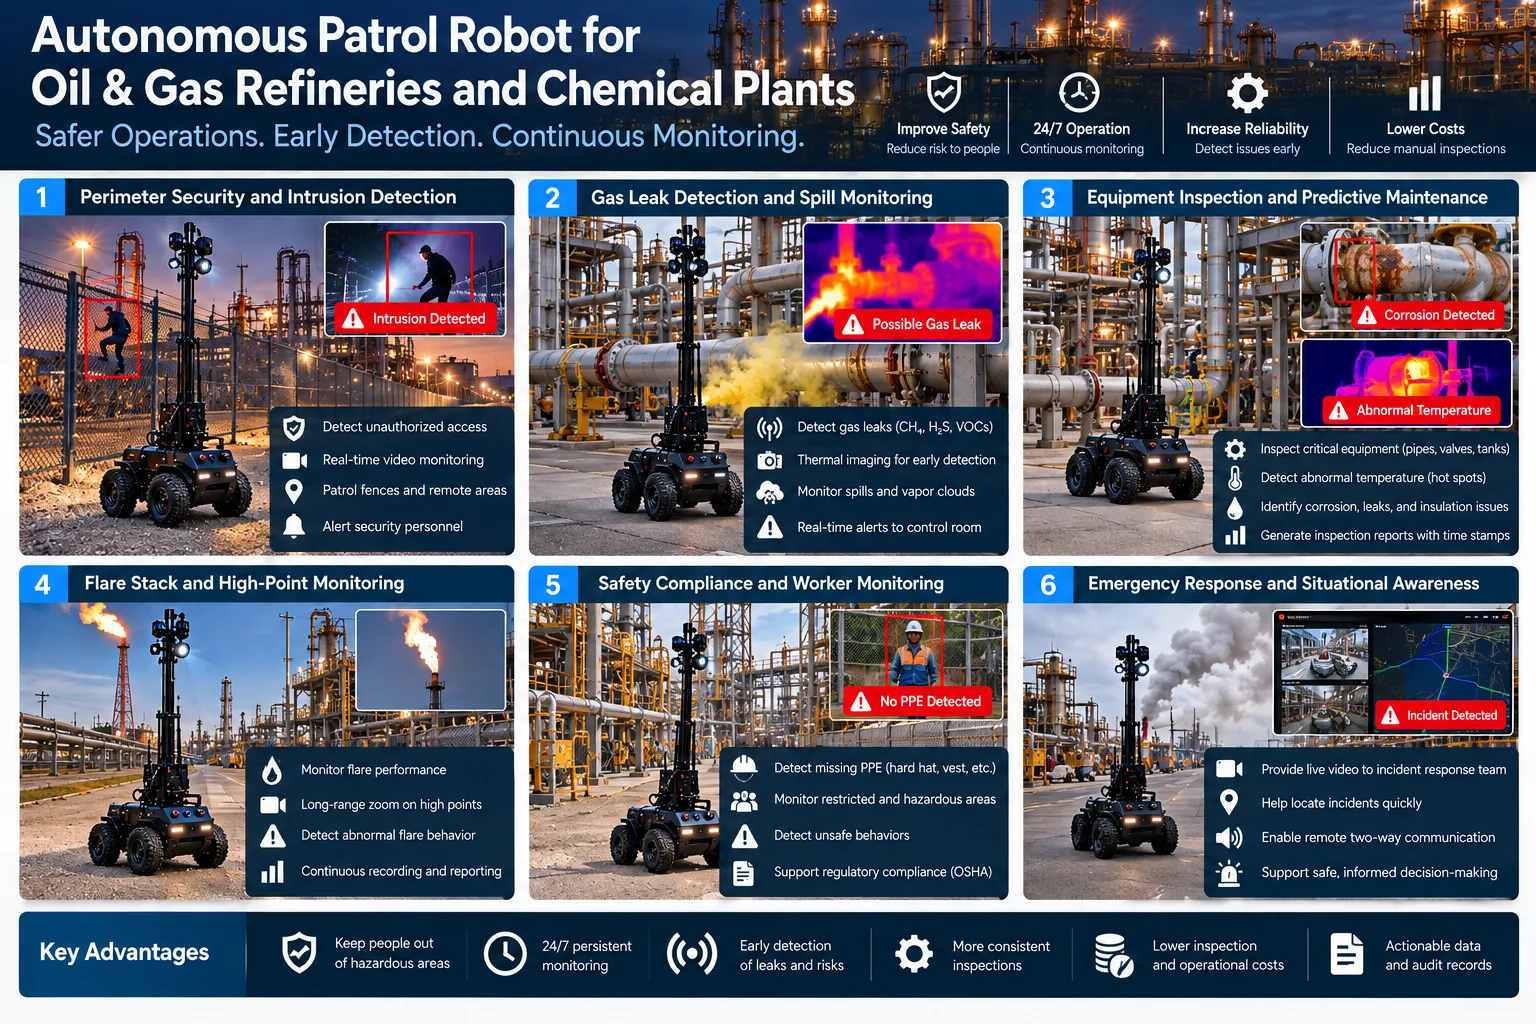
Remote visual inspection, perimeter awareness and configurable environmental sensing.
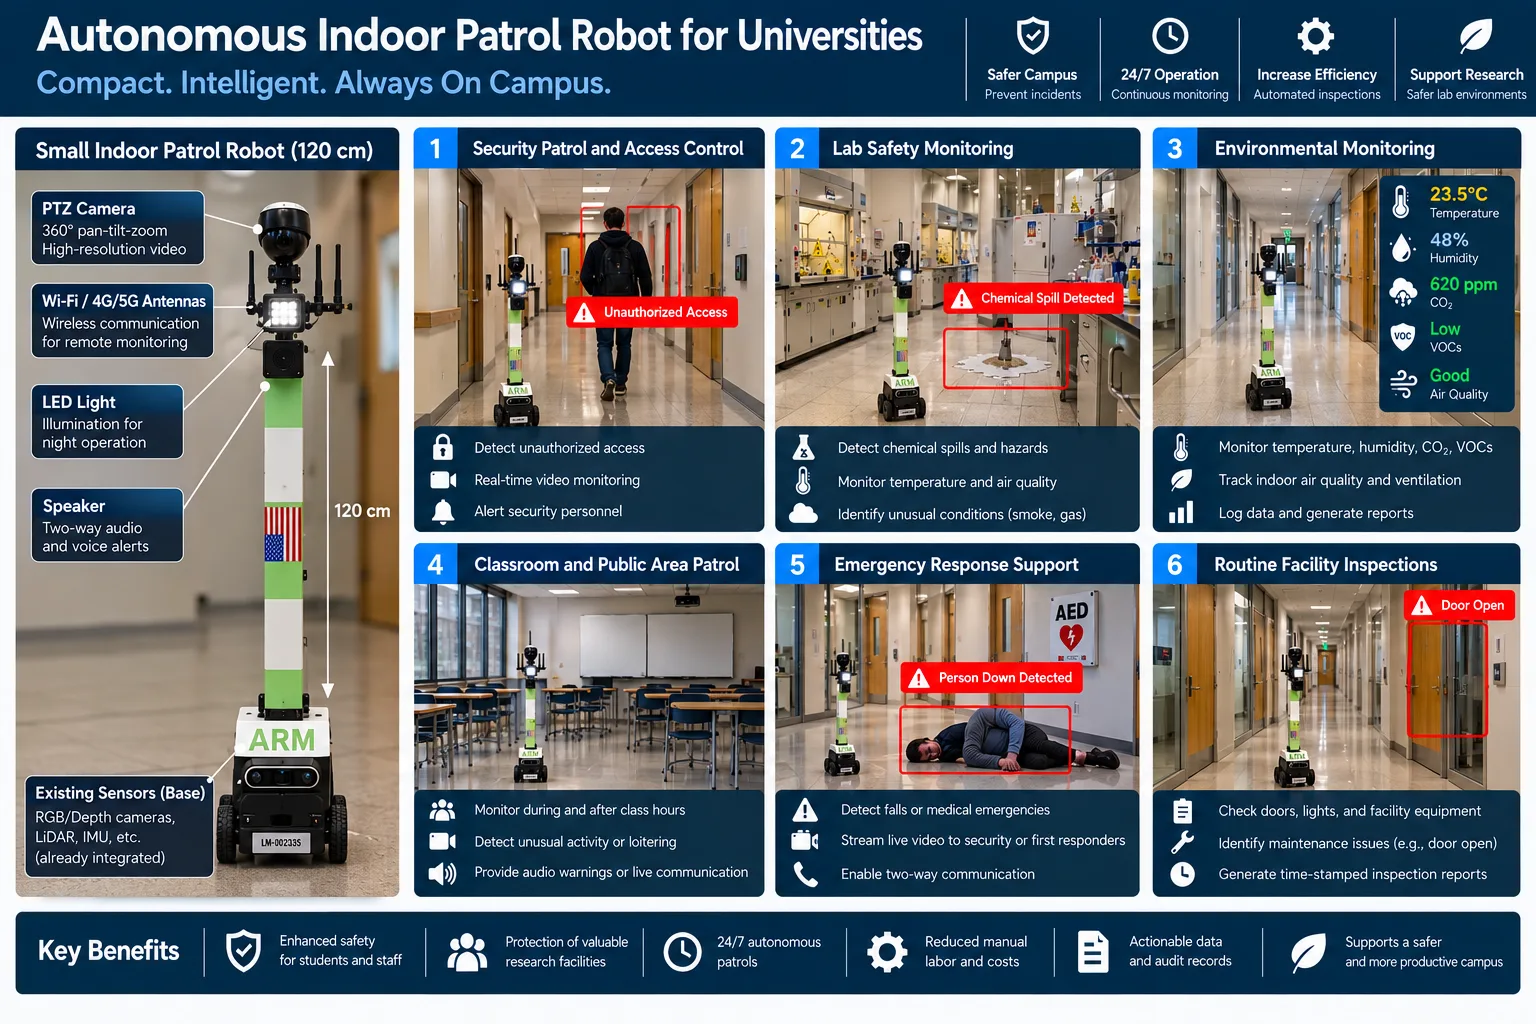
Concepts for indoor security, laboratory monitoring and routine building inspections.
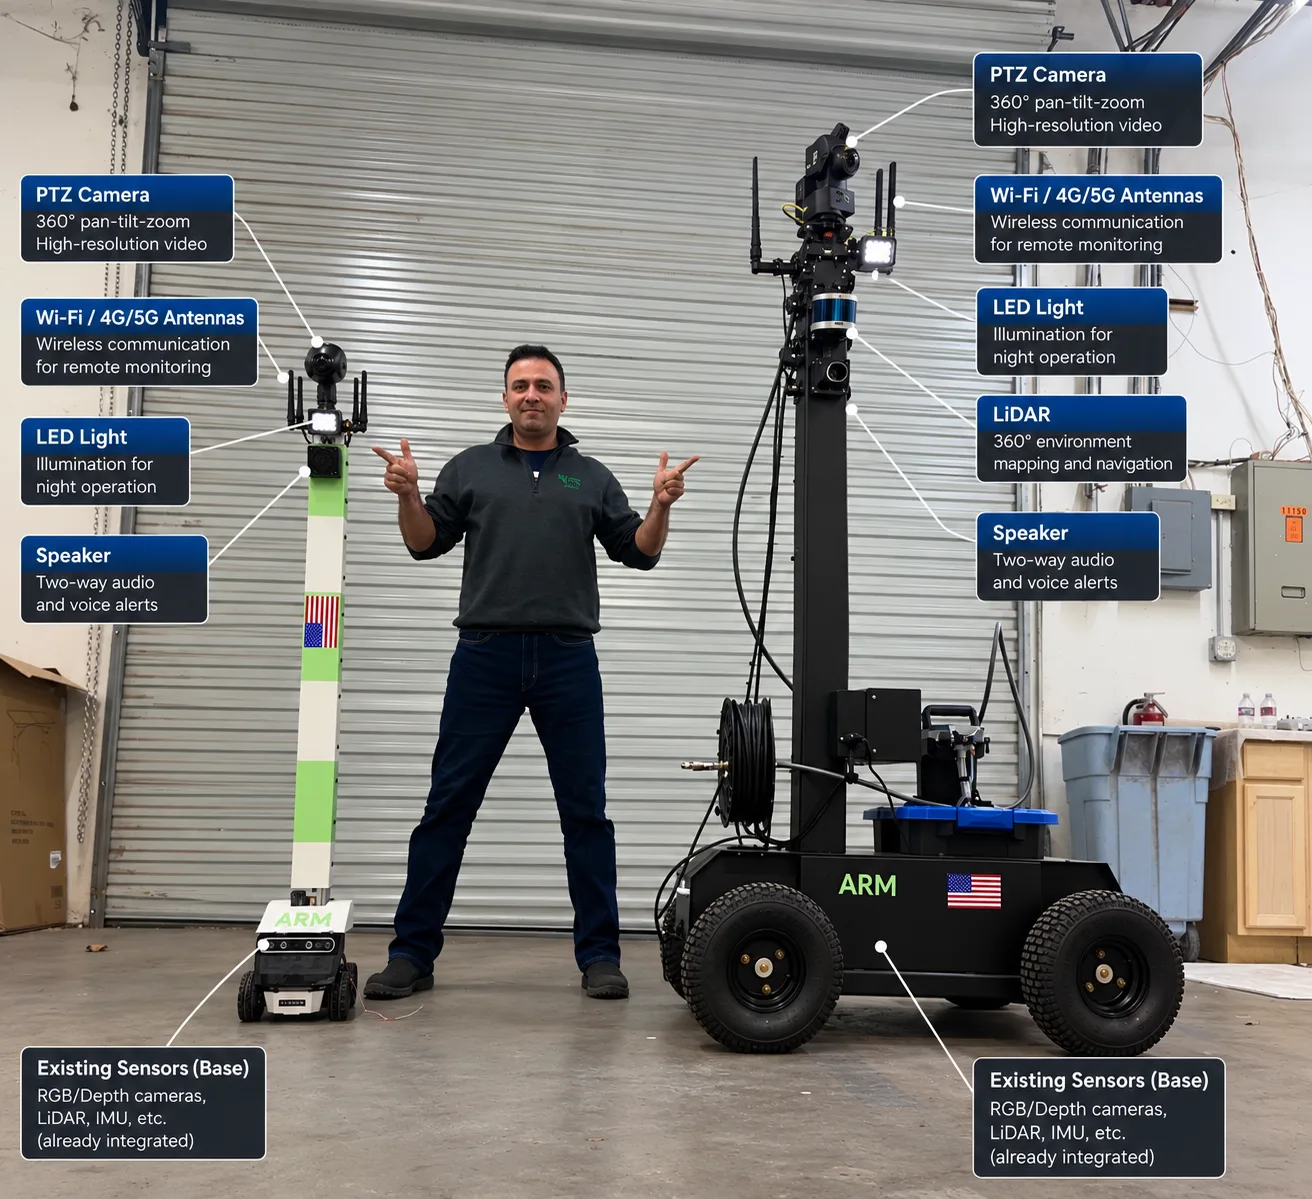
Multiple form factors for corridors, campuses, commercial sites and large open spaces.
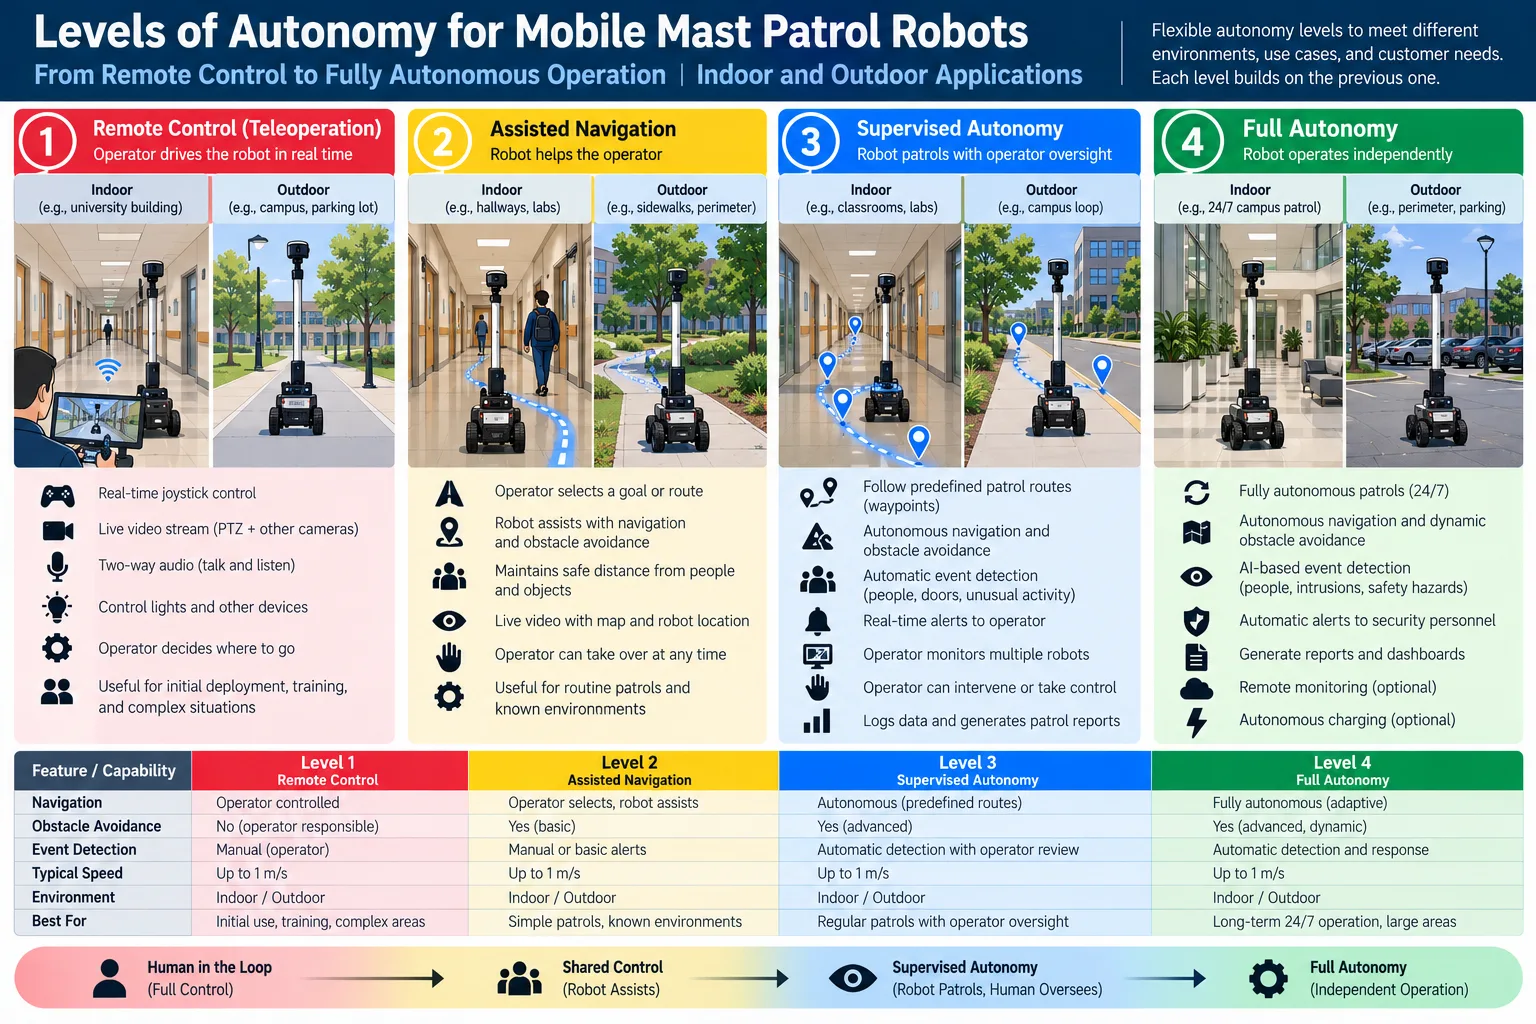
From operator-driven control to progressively more capable autonomous operation.
Different customers need different levels of operator involvement. Our development approach progresses from direct remote operation toward more advanced navigation and patrol functionality.
Human operator drives the robot and manages its onboard sensors.
Navigation aids and obstacle awareness assist the operator.
Predefined patrol routes with human oversight and intervention.
Long-term vision for independent patrol and automated reporting.
These stages describe a proposed capability roadmap; they do not imply all levels are currently commercially available.
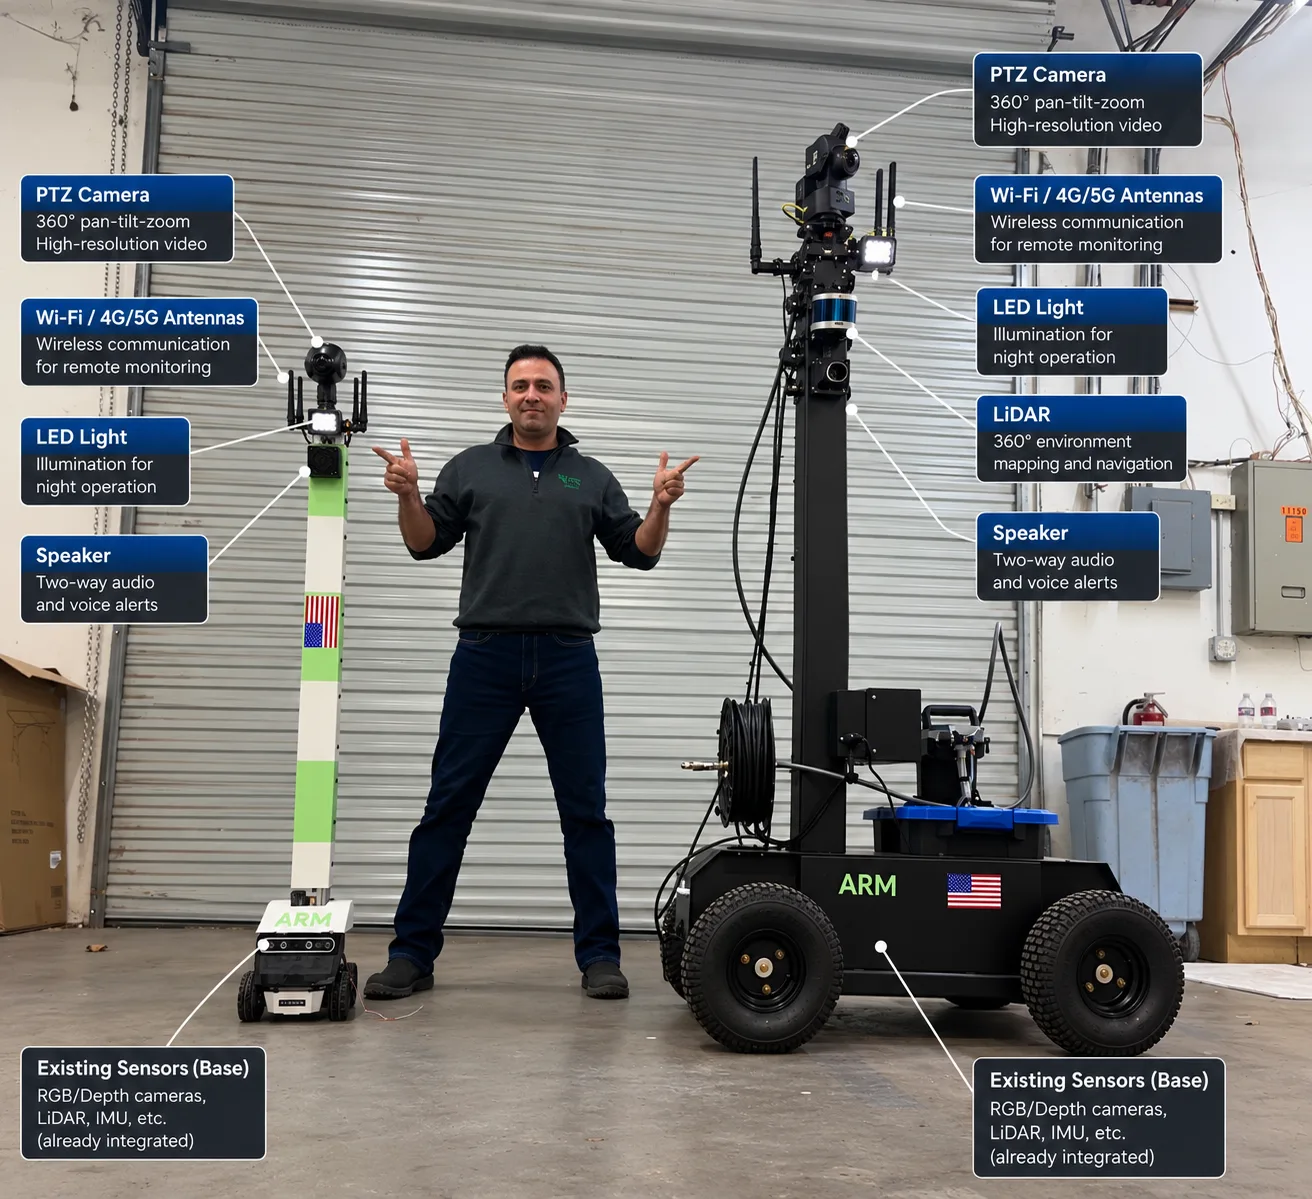
ARM Robotics develops mobile robotic systems that bring sensing and monitoring to places conventional fixed cameras cannot easily reach. Our approach combines mechanical innovation, flexible payload integration and a phased path toward autonomy.
Amir Jafari is an Associate Professor of Biomedical Engineering at the University of North Texas and the founder of ARM Robotics. He earned his Ph.D. from the Illinois Institute of Technology and completed postdoctoral research at ETH Zurich, Switzerland.
His research spans advanced robotic manipulators, variable-stiffness actuators, soft robotics and human–robot interaction. Through ARM Robotics, he applies this experience to the development of mobile surveillance platforms, industrial automation technologies and robotic painting systems.
His work brings together mechanical design, sensing and intelligent control to address practical engineering challenges.
We welcome conversations about pilot projects, platform customization, technology integration and partnerships.
Email ARM RoboticsContact address is a placeholder. Replace it with your verified company email before publishing.